|
Ryo Takizawa I am a second-year phD student at the University of Tokyo. I am a member of Intelligent Systems and Informatics Laboratory (2023-). I received my Master’s degree from the Graduate School of Information Science and Technology at the University of Tokyo (2023-2025) and my Bachelor’s degree from the Department of Precision Engineering, the University of Tokyo (2019-2023). My main research focus is to make robots more intelligent. Rather than merely focusing on factory automation technology, I aim to develop methodologies that enable robots to adaptively expand their capabilities in real-world environments, much like humans do. With this objective, both my master's research and my doctoral research primarily focus on robotic object manipulation. |
|
Publications |
|
|
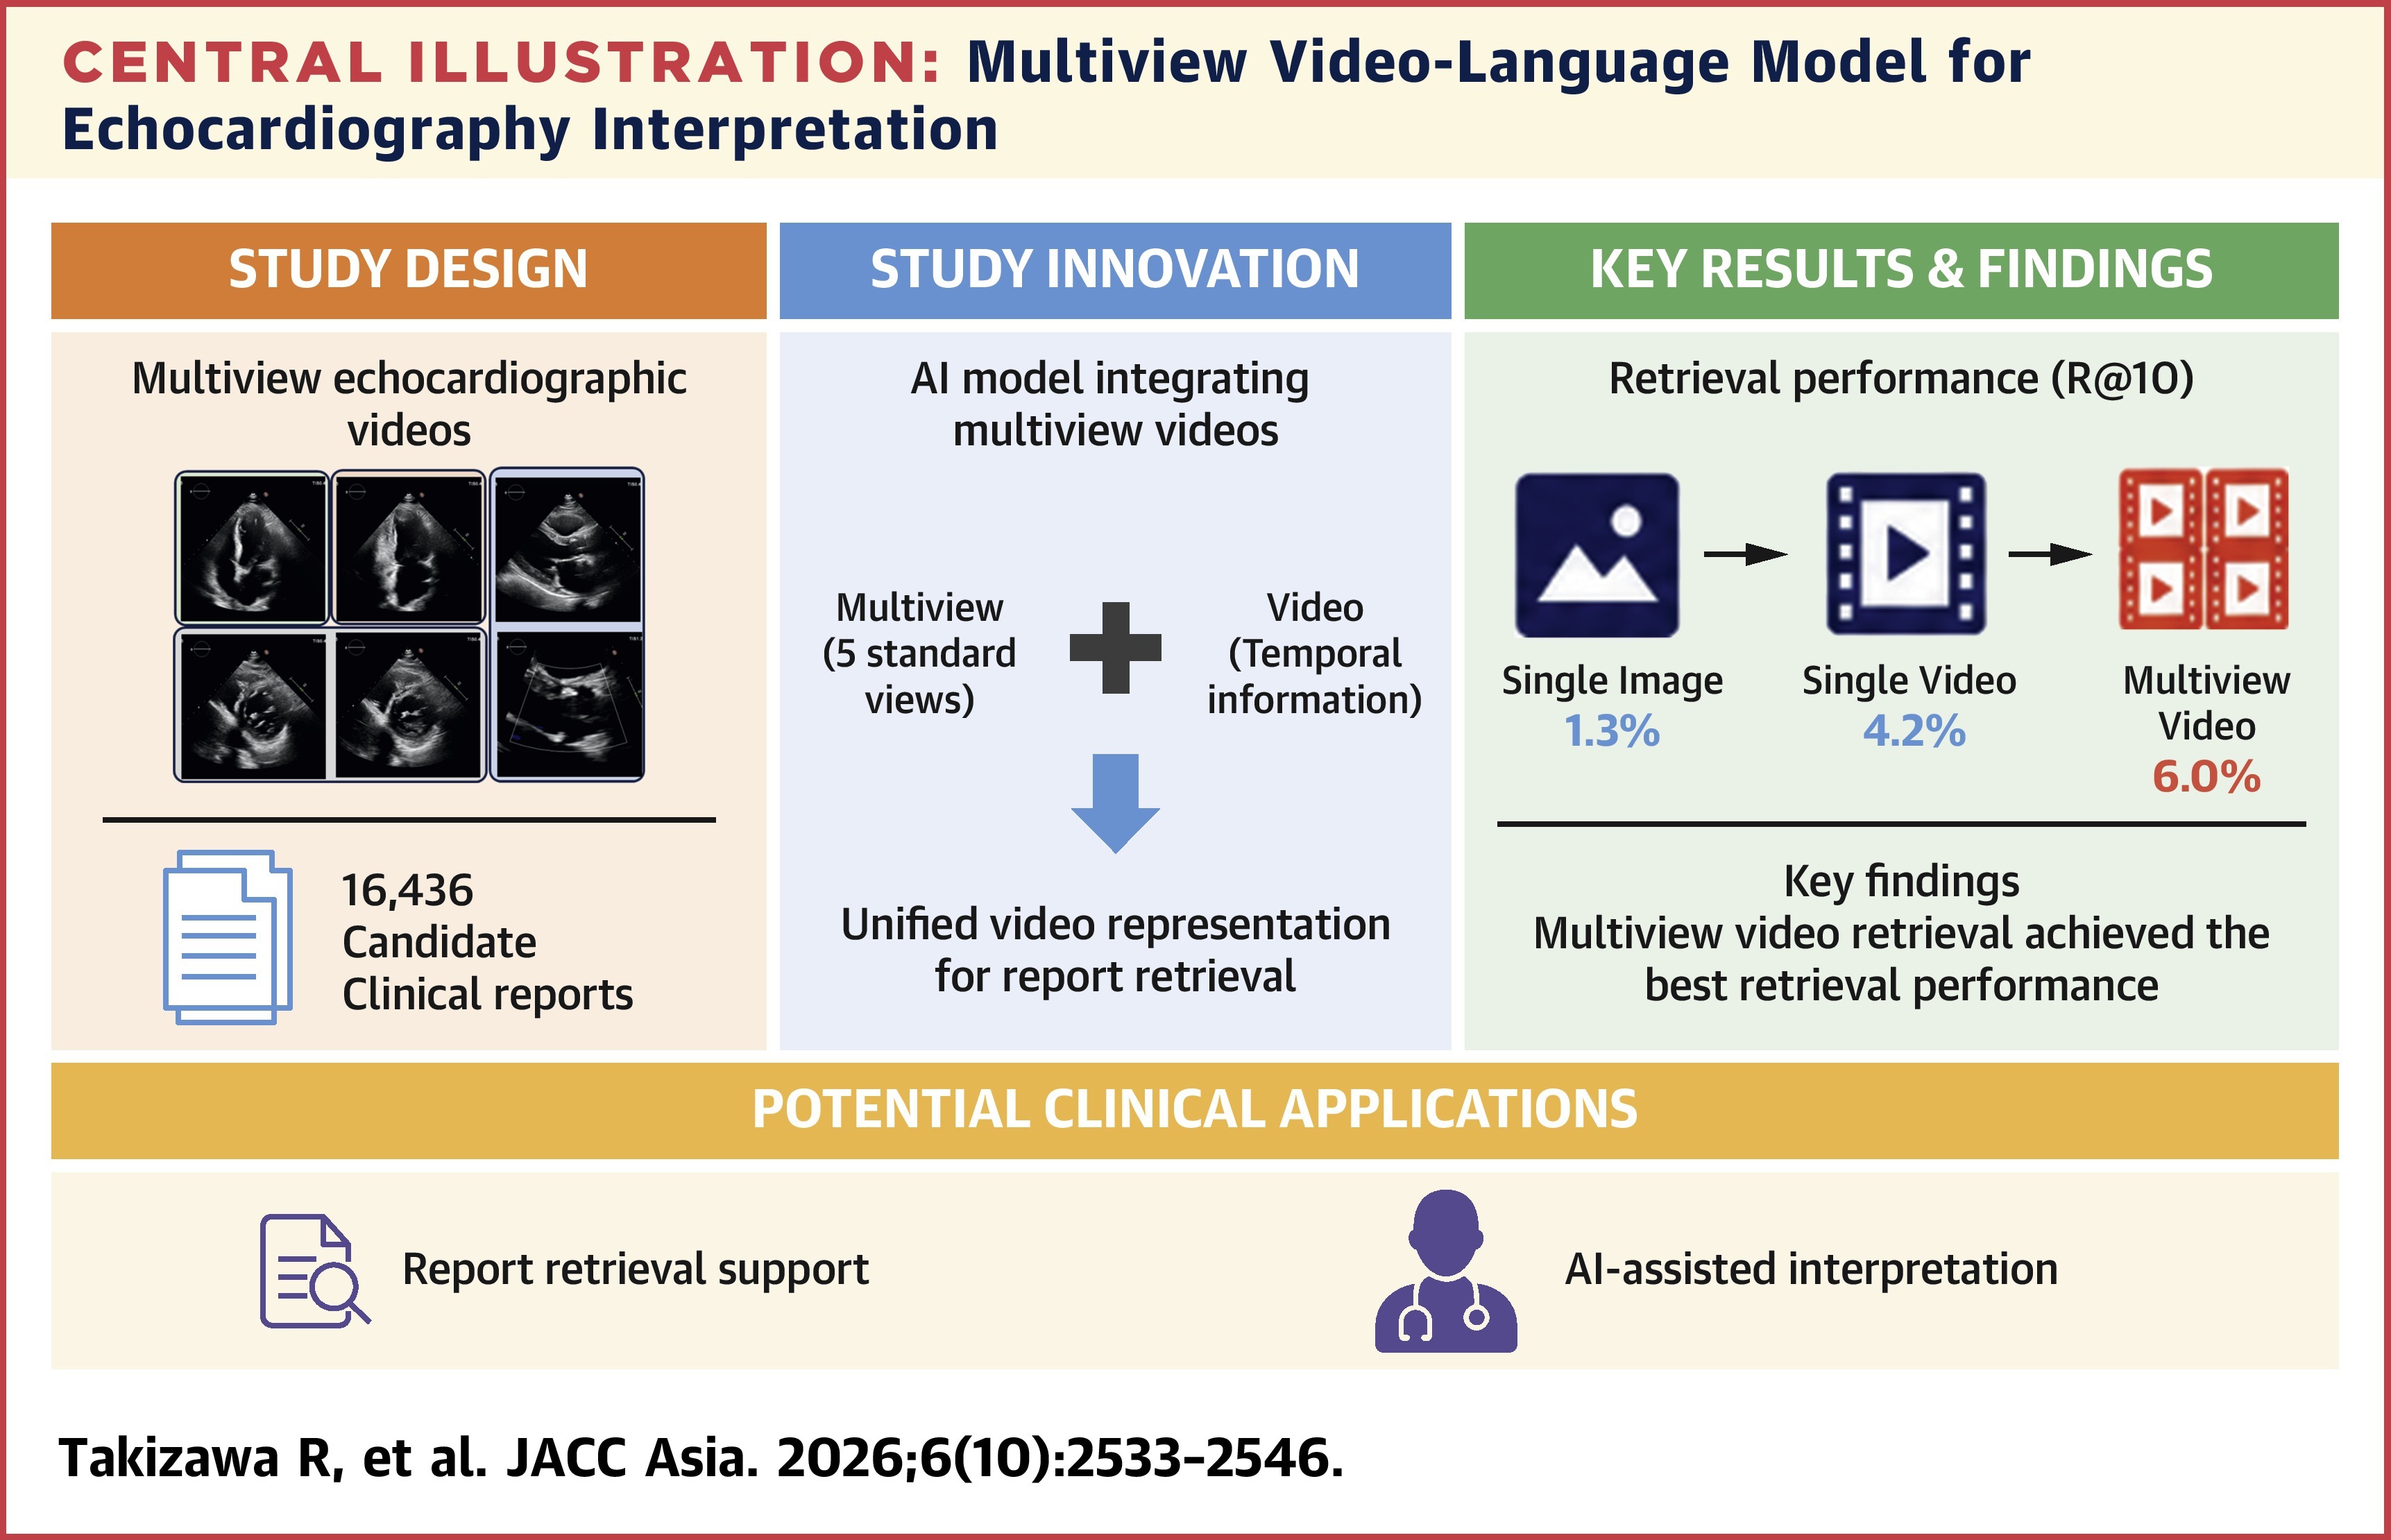
Comprehensive Echocardiography Interpretation Using Video and Multiview Vision-Language AI
Ryo Takizawa, Chiemi Yamazaki, Satoshi Kodera, Tempei Kabayama, Shun Kitamura, Risa Kishikawa, Ryo Matsuoka, Megumi Hirokawa, Junichi Ishida, Koki Nakanishi, Hiroyuki Morita, Norihiko Takeda JACC: Asia, 2026 paper |
|
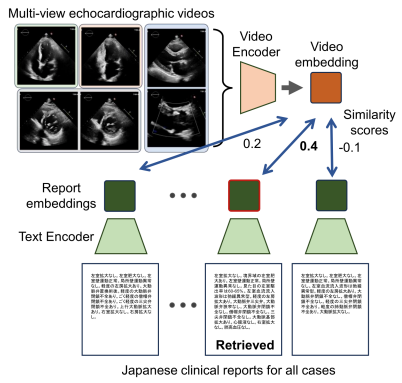
Video CLIP Model for Multi-View Echocardiography Interpretation
Ryo Takizawa*, Satoshi Kodera, Tempei Kabayama, Ryo Matsuoka, Yuta Ando, Yuto Nakamura, Haruki Settai, Norihiko Takeda NeurIPS Workshop TS4H, 2025 paper / code |
|
Enhancing Reusability of Learned Skills for Robot Manipulation via Gaze
Information and
Motion Bottlenecks
Ryo Takizawa*, Izumi Karino, Koki Nakagawa, Yoshiyuki Ohmura, Yasuo Kuniyoshi IEEE RA-L, 2025 website / paper / code |
|
|
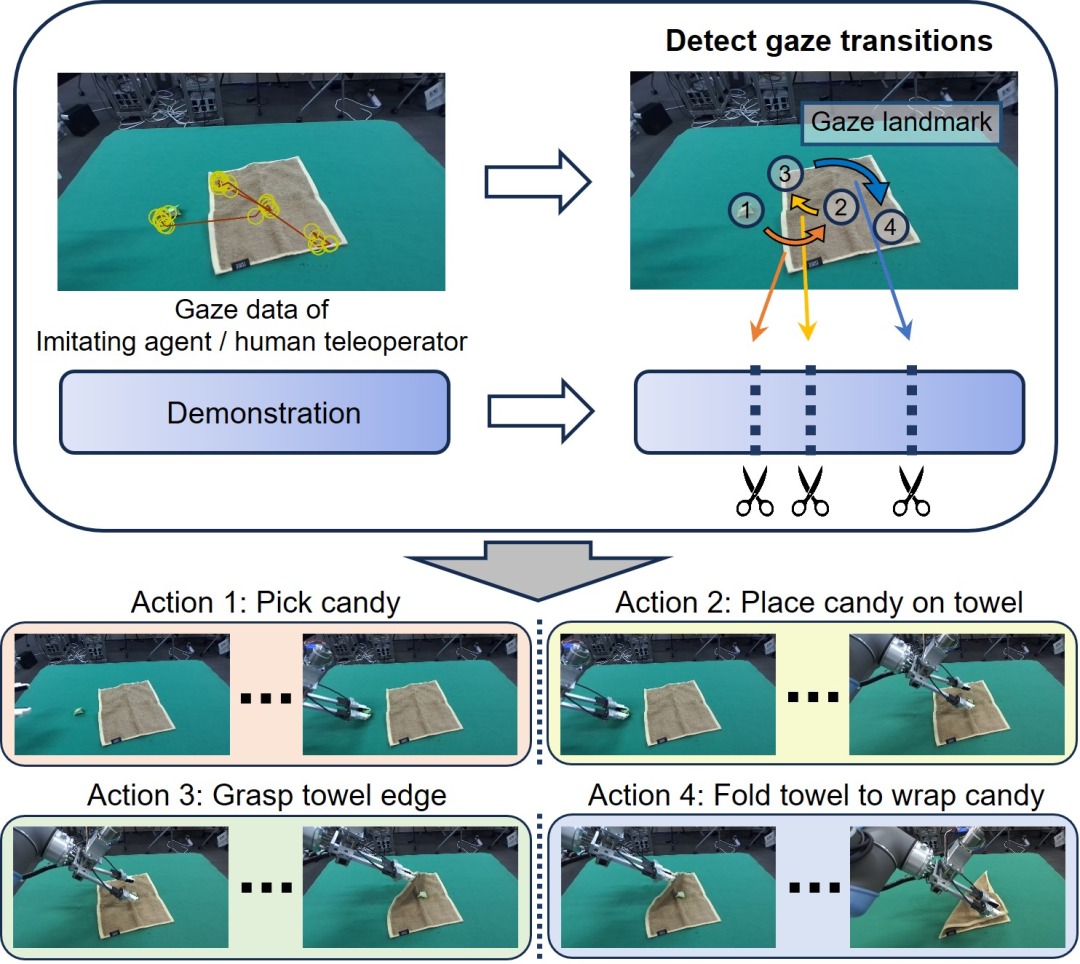
Gaze-Guided Task Decomposition for Imitation Learning in Robotic
Manipulation
Ryo Takizawa*, Yoshiyuki Ohmura, Yasuo Kuniyoshi IROS, 2025 paper / code |
|
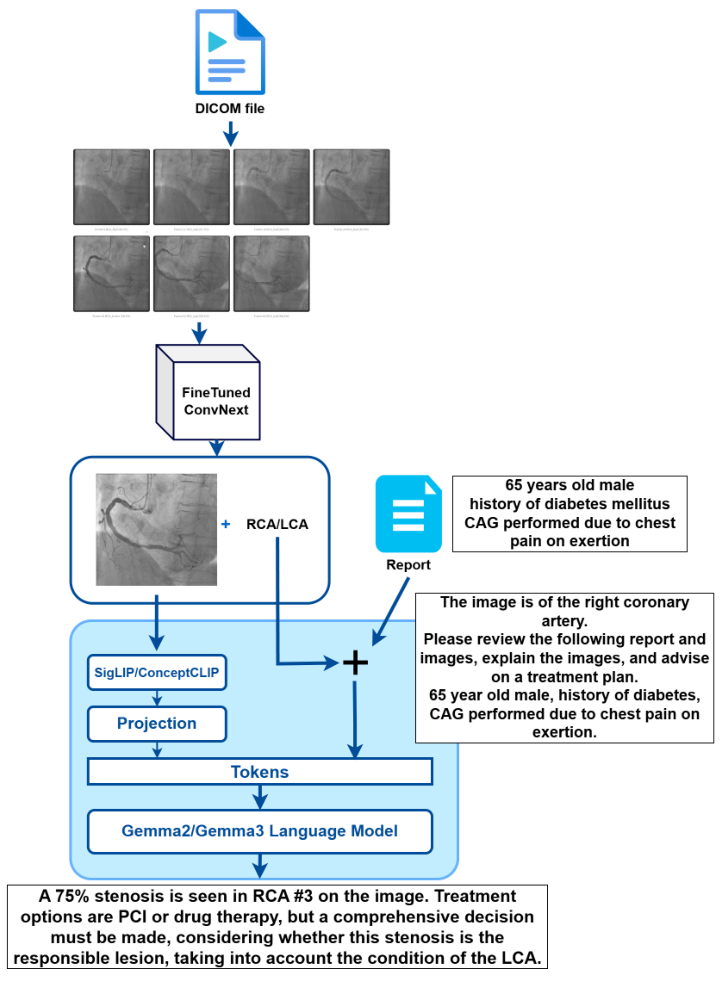
CAG-VLM: Fine-Tuning of a Large-Scale Model to Recognize Angiographic Images for Next-Generation Diagnostic Systems
Yuto Nakamura, Satoshi Kodera, Haruki Settai, Hiroki Shinohara, Masatsugu Tamura, Tomohiro Noguchi, Tatsuki Furusawa, Ryo Takizawa, Tempei Kabayama, Norihiko Takeda CVPR Workshop CVinW, 2025 paper |
|
No Image
|
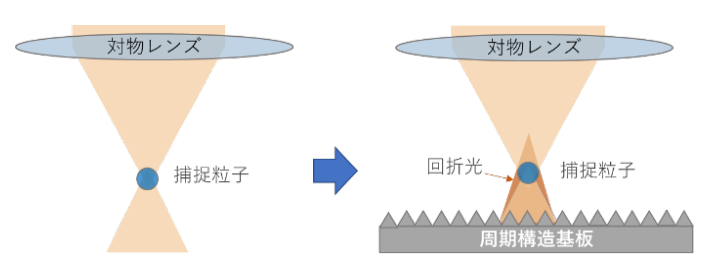
周期構造基板上光捕捉におけるマイクロ粒子の光軸に沿った移動現象
吉川 瑞紀, 涔澤 諒, 門屋 祥太郎, 道畑 正岐, 小玉 脩平, 宮地 悟代, 高橋 哲 第71回応用物理学会春季学術講演会, 23p-12B-4, 2024 |
|
周期構造基板を用いたマイクロ物体の光捕捉・駆動に関する基礎的研究(第1報)—捕捉した微小球の駆動とその性質の実験的解明
涔澤 諒, 門屋 祥太郎, 道畑 正岐, 高橋 哲, 小玉 脩平, 宮地 悟代 2023年度精密工学会春季大会学術講演会, 2023 paper |
Preprints |
|
|
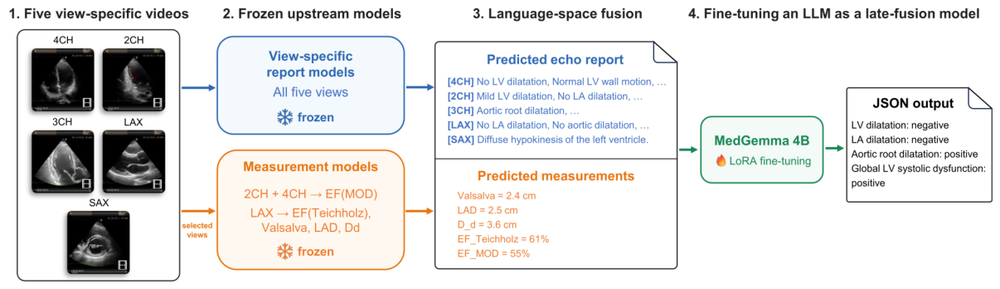
Integrating Heterogeneous Echocardiography AI Outputs in Language Space: Learnable Late Fusion with a Supervised LLM
Ryo Takizawa, Tempei Kabayama, Chiemi Yamazaki, Shun Kitamura, Ryo Matsuoka, Yuta Ando, Satoshi Kodera, Norihiko Takeda arXiv preprint, 2026 paper |
|
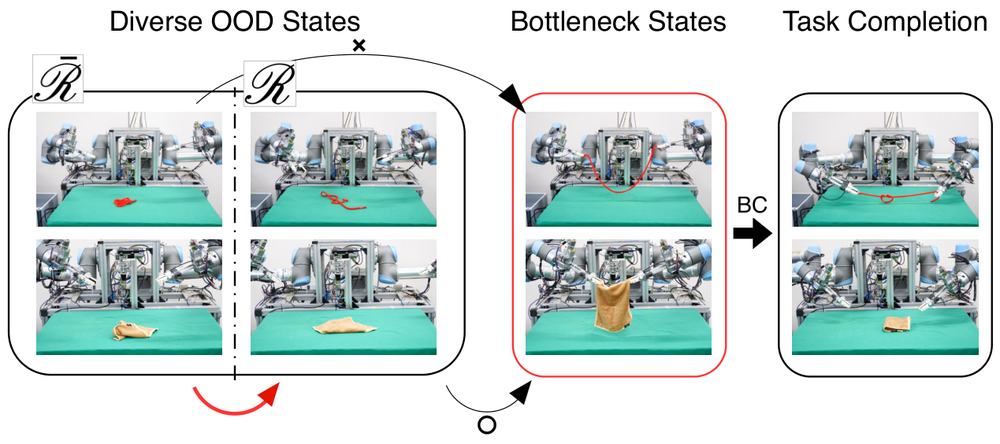
Exploration-assisted Bottleneck Transition Toward Robust and Data-efficient Deformable Object Manipulation
Yujiro Onishi, Ryo Takizawa, Yoshiyuki Ohmura, Yasuo Kuniyoshi arXiv preprint, 2026 paper |
Work Experience |
|
|
Research Engineer
The University of Tokyo Hospital – Research on vision-language models and AI agents for echocardiography. |
Other Work |
|
|
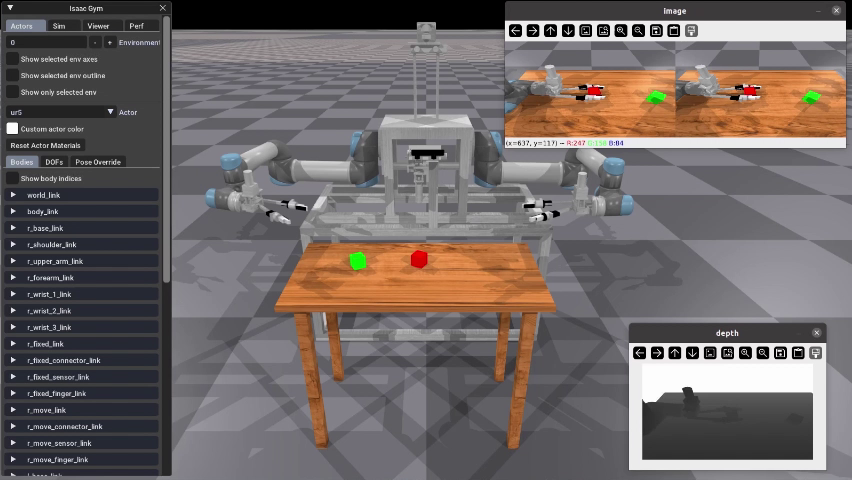
Tong Simulator
simulator GitHub / API GitHub A simulator for the ISI Lab dual-arm robot "Tong System". |
|
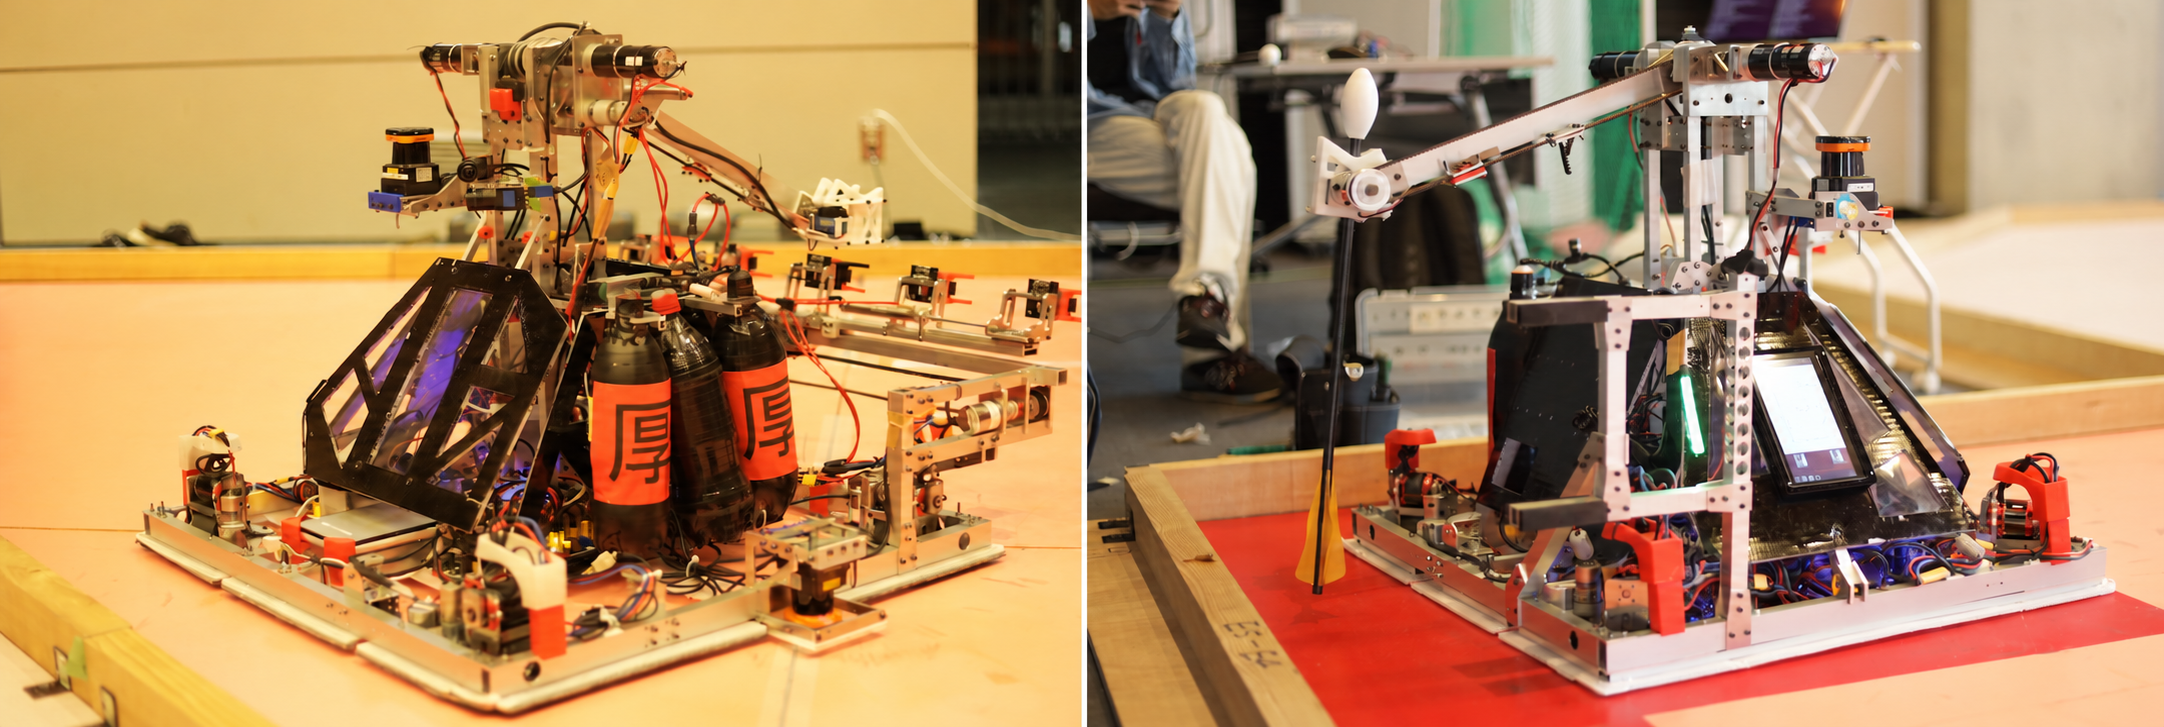
ABU Robocon 2021
– website |
|
|
NHK Robocon 2021
– website |
|
|